
TL;DR: An RTK network is the physical infrastructure of reference stations that generates GNSS corrections. Network RTK is one method of computing them, interpolating a virtual reference station from several surrounding sites. The two terms are not interchangeable. Single-baseline and Network RTK both deliver centimeter accuracy on a dense network, and which one you use is a configuration choice, not a fixed decision.
Key takeaways
- An RTK network is infrastructure: reference stations at precisely surveyed locations, connected to a service that distributes corrections.
- Network RTK is a correction method that uses several of those stations at once to synthesize a Virtual Reference Station (VRS) at your rover’s location.
- Single-baseline RTK and Network RTK both deliver 1 to 3 cm accuracy and are both OSR approaches. Neither is better in general; they have different operational strengths.
- Both are available within Point One’s True RTK service, and you can set a profile that starts on one and falls back to the other as conditions require.
- Accuracy falls roughly 1 to 1.5 cm per 10 km of added distance from the nearest station, which is why inter-station spacing matters more than total coverage area.
An RTK network is the ground infrastructure that makes centimeter-level satellite positioning possible. It consists of GNSS (Global Navigation Satellite System) reference stations installed at precisely surveyed locations, connected to a service that streams correction data to receivers in the field. Where a standalone GNSS receiver is accurate to within 3 to 10 meters, a receiver applying corrections from an RTK network is accurate to within 1 to 3 centimeters.
This guide covers what an RTK network is, how it differs from Network RTK (a distinction the industry uses loosely and marketing often muddles), how the correction methods compare, and what to evaluate before committing to a provider.
What Is an RTK Network?
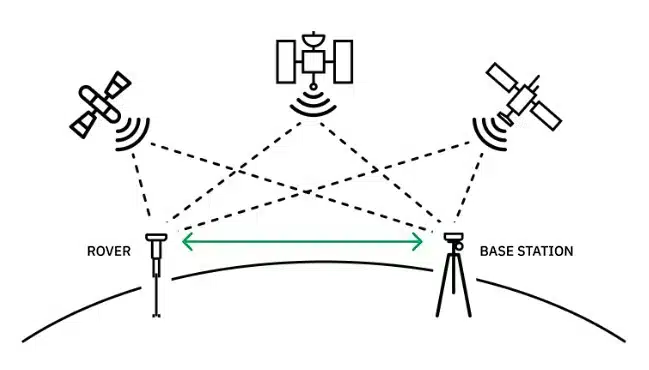
An RTK network is a set of interconnected GNSS reference stations, also called base stations, that continuously observe satellite signals and generate correction data for receivers operating nearby.
Each station sits at a location surveyed to within a centimeter or two. Because the station knows exactly where it is, it can compare the satellite measurements it observes against the measurements it should observe, and the difference becomes a correction. A rover, meaning your receiver in the field, applies that correction to cancel the same errors from its own measurements.
What makes it a network rather than a collection of standalone stations is the central service tying them together. That service handles station selection, monitors station health, and delivers corrections over the internet using NTRIP, or in some cases over L-Band satellite. You connect once and the network routes you appropriately, rather than manually choosing a station every time you move.
Real-time kinematic (RTK) is the positioning technique itself. The network is the infrastructure that supplies it. For the technique in depth, see What is RTK? For the mathematics of how a receiver converts corrections into a centimeter-level position, see How Does RTK Fixing Work?
RTK Network vs. Network RTK: What Is the Difference?
An RTK network is infrastructure. Network RTK is a method of using that infrastructure. The terms sound interchangeable and are frequently swapped, but they answer different questions.
| What it refers to | The question it answers | |
|---|---|---|
| RTK network | The physical reference stations plus the service that distributes their corrections | Where can I get corrections, and how good is the infrastructure? |
| Network RTK | A correction method that interpolates several stations into one virtual station | How are the corrections computed for my specific location? |
You can access single-baseline corrections from an RTK network without using Network RTK at all. And Network RTK is only possible if an RTK network exists underneath it, with enough stations to interpolate between. One is the road; the other is a way of driving on it.
Two methods share the same underlying observations, and a third takes a different approach entirely.
Single-Baseline RTK
Single-baseline RTK connects your rover to the nearest physical station and applies its corrections directly. This is where the technology started, and it remains the most transparent option.
The correction chain is fully deterministic. You know which station supplied the data, you have the raw observations, and you can replay the exact inputs to reproduce a given position. For anyone debugging an anomaly in an autonomous system, that traceability is worth a great deal. Degradation is also visible: as baselines lengthen, you see longer fix times and float solutions rather than fixed ones, so you can design your system to respond to a signal you can actually observe.
The limitation is distance. Corrections from one station describe atmospheric conditions near that station. Performance typically begins degrading beyond roughly 30 to 40 km.

Network RTK and How VRS Works
Network RTK uses observations from several surrounding stations simultaneously rather than relying on the single closest one. The process runs server-side in four steps:
- Collect. The network gathers raw observations from the stations surrounding your rover’s reported position.
- Model. Using the known geometry between those stations, the server interpolates ionospheric and tropospheric conditions across the area between them.
- Synthesize. It estimates what a station at your rover’s exact location would observe if one existed there.
- Stream. It sends that synthesized observation data to your rover as a Virtual Reference Station (VRS).
Your receiver cannot tell the difference. It treats a VRS stream like a nearby physical base, which is why Network RTK works with standard receivers and requires no special firmware.
An important clarification: VRS is a delivery format, not a correction method. A decade ago the two were effectively synonymous, because Network RTK was the only thing generating virtual stations. Today a VRS stream can be produced by interpolating real observations (Network RTK) or by running physics models server-side and converting the output to standard RTCM (SSR-based). Both look identical to a rover, but their accuracy characteristics differ because the underlying methods differ. When a provider says they deliver VRS corrections, that tells you the format. Ask what is behind it.
Both single-baseline RTK and Network RTK are OSR (Observation Space Representation) approaches. Both work from real observations made at real stations. The interpolation in Network RTK happens at the observation level, which means its accuracy is bounded by how densely those real stations sample the atmosphere, not by how sophisticated the interpolation algorithm is.

Choosing Between Them, and Switching
Single-baseline and Network RTK are frequently framed as competing approaches, which forces teams to commit early in development to something they cannot yet evaluate. They are better understood as two configurations of the same service, each with different operational characteristics.
Single-baseline gives you a deterministic, replayable correction chain and degradation you can observe directly. Network RTK gives you redundancy, so a station going offline for maintenance or hardware failure does not interrupt your operation, and better midfield performance when your rover sits roughly equidistant from several stations, since using all of them yields more information than using only the closest. That midfield advantage is most noticeable with lower-cost receivers, which benefit from having more data to work with.
Neither is categorically better. The right answer depends on whether traceability or redundancy matters more for your application, and that often changes as a program moves from prototype to production.
Point One delivers both within True RTK, on the same network and through the same integration. As of the launch of Network RTK within True RTK, you can run either one, switch between them without changing your workflow, or configure a profile that starts on single-baseline and falls back to Network RTK when conditions call for it. The practical effect is that you can evaluate both against your own hardware and operating environment rather than picking a side on a datasheet.
For a detailed treatment of the tradeoffs, including how atmospheric conditions constrain both methods and how to evaluate a provider’s real-world rather than median performance, see Demystifying Network RTK: What Drives Correction Accuracy and Why Density Matters.
SSR Corrections (Virtual RTK)
SSR (State Space Representation) takes a different path. Rather than interpolating observations, it decomposes GNSS error into its physical components (satellite orbits, satellite clocks, ionospheric delay, tropospheric delay, and signal biases) and models each one separately. Because one broadcast stream serves every user regardless of location, SSR scales to continental coverage from far fewer stations.
The historical catch was that rovers needed specialized firmware to reconstruct corrections from model parameters. Point One’s Virtual RTK runs SSR modeling on the backend and converts the output to standard RTCM messages, so any dual-band RTK receiver can consume it. Accuracy lands at 3 to 7 cm with roughly 30-second convergence, which suits automotive ADAS, IoT, and large fleets where wide-area consistency matters more than sub-centimeter precision.
Comparing the Methods
| Single-Baseline RTK | Network RTK (VRS) | SSR | |
|---|---|---|---|
| Method | Nearest physical station | VRS interpolated from several stations | Error components modeled separately |
| Format | OSR | OSR | SSR backend, OSR to rover |
| Accuracy | 1 to 3 cm | 1 to 3 cm | 3 to 7 cm |
| Convergence | Immediate | Seconds | Approximately 30 seconds |
| Coverage | Roughly 30 to 40 km from station | Within network footprint | Continental |
| Receiver | Any dual-band RTK receiver | Any dual-band RTK receiver | Any dual-band RTK receiver |
| Strengths | Traceability, visible degradation | Redundancy, midfield performance | Scale, wide-area consistency |
| Point One service | True RTK | True RTK | Virtual RTK |
Note the last row: single-baseline and Network RTK are both delivered within True RTK, which is why switching between them is a configuration change rather than a migration.
Why Station Density Matters More Than Correction Type
Correction accuracy is governed by physics, not by which method you pick.
GNSS signals pass through the ionosphere and troposphere, and both introduce delays that vary across space and time. Broad, slow-moving patterns are well modeled and account for most of the effect. What remains is localized, high-frequency variation, and that residual determines your accuracy in the moments that matter. No model, however sophisticated, can recover detail that was never sampled.
The practical consequence: accuracy degrades roughly 1 to 1.5 cm per 10 km of added distance from the nearest station, and that relationship constrains single-baseline RTK, Network RTK, and SSR equally. Dense networks with 30 to 40 km average spacing keep the whole error distribution tight. Sparse networks often show comparable average accuracy while producing much longer tails, and it is the tail, not the median, that causes a line painter to paint a crooked line or an autonomous mower to drift into a flowerbed.
This is why the most useful question to ask a provider is about inter-station spacing, not correction type. The full technical breakdown covers why you should evaluate excursion rates at the 99th percentile rather than median accuracy.
One related trap: your receiver’s published RTK specification sets a floor on achievable accuracy, and no correction service can exceed what the hardware is capable of. Datasheet figures also tend to describe ideal conditions rather than field performance. 6 GPS and GNSS Mistakes That Derail Localization System Design covers that gap in detail.
How an RTK Network Works
Corrections travel from satellite to station to rover in five steps.
- Stations observe. Reference stations continuously track carrier-phase observations across every constellation they support, typically GPS, GLONASS, Galileo, and BeiDou. Multi-constellation tracking improves satellite availability and fix reliability.
- Errors are computed. Each station compares what it observes against what its known position says it should observe, isolating atmospheric, orbital, and clock error.
- Corrections are encoded. Error data is packaged as RTCM 3.x messages, the industry standard format.
- Corrections are delivered. Messages reach your rover over NTRIP via cellular or internet, over a UHF or VHF radio link from a local base, or over L-Band satellite where cellular is unavailable.
- The rover resolves and positions. Your receiver combines corrections with its own observations, resolves integer ambiguities, and outputs a position accurate to a few centimeters.
Correction age matters throughout. Most receivers accept OSR corrections up to roughly 60 seconds old, but performance degrades as latency climbs, and corrections should ideally arrive within 1 to 2 seconds. For a fuller treatment of how corrections are generated, encoded, and delivered, see RTK Corrections: What They Are and How They Work. For how the protocol layer works, see What is NTRIP?
Not every receiver can use RTK corrections. You need a dual-frequency receiver capable of carrier-phase measurement and integer ambiguity resolution; consumer GNSS chips in phones and handhelds cannot. Our GNSS receiver guide covers hardware selection.
Public vs. Private RTK Networks
Public networks are operated by government agencies, universities, and community projects, and are usually free. Private networks operate commercially under subscription. The differences that matter in production are not primarily about accuracy.
| Public networks | Private networks | |
|---|---|---|
| Cost | Free or low cost | Subscription |
| Uptime commitment | Generally none | Contractual SLA typically available |
| Monitoring | Varies, often limited | Continuous, with alerting and failover |
| Station spacing | Uneven; some networks space stations up to 70 km apart | Varies by provider; ask for actual spacing |
| Support | Limited or none | Included, with defined escalation |
| Fleet provisioning | Manual | API-based on developer-oriented services |
| Best for | Occasional field work, prototyping, education | Production systems, fleets, continuous operation |
Public CORS (Continuously Operating Reference Station) networks work well for traditional survey workflows, where an operator is present, can see a degraded solution, and can recollect a point. They are a poorer fit for autonomous systems, where nobody is watching and a silent correction outage produces plausible-looking but wrong positions.
One distinction worth probing on the private side: whether a provider owns and operates its stations, or aggregates third-party and crowd-sourced infrastructure. Owned networks give consistent installation quality, uniform hardware, and centralized monitoring. Aggregated and incentive-driven networks vary in antenna quality, siting, and continuity.
What that looks like in practice: Point One’s stations are professionally installed and run dual cellular modems with four SIM slots each, so a regional carrier outage does not take a station offline. Each has five days of battery backup. Position integrity is monitored automatically, and a station that detects physical displacement removes itself from the network rather than continuing to broadcast corrections derived from a coordinate that is no longer correct. That last point matters more than it sounds: a displaced station produces positions that look internally consistent while being systematically wrong, which is the hardest class of error to catch in the field.
How to Choose an RTK Network
Five questions separate networks that demo well from networks that hold up in production:
- What is the inter-station spacing in my operating area? Ask for station locations, not shaded coverage regions.
- What are excursion rates at the 99th percentile? Median accuracy is easy to publish. Tail behavior is what your system depends on.
- Does the provider own and operate its stations?
- Can I trace and replay the full correction chain? You will want this the first time you debug a field failure.
- Is provisioning programmatic? Manually configuring hundreds of devices does not scale.
A sixth question is worth asking if you are early in development: can you access more than one correction method on the same service, without re-integrating? Being able to test single-baseline and Network RTK against your own hardware is more useful than any datasheet comparison.
For the complete evaluation framework, including a side-by-side comparison of the commercial, government, and community networks operating in the US and globally, see our guide to NTRIP service providers. For an eight-factor technical checklist covering protocol compatibility, constellation support, security, and pricing structure, see How to Choose the Best RTK. If you are weighing a network against deploying your own hardware, Is Building Your Own RTK Worth It? has a three-year cost comparison.
If you are selecting corrections as part of a broader localization system, The 7 V-Model Stages of Localization System Design covers where that decision belongs in the development cycle, and why changing it later gets expensive.
What RTK Networks Are Used For
RTK networks support any application where positioning error has a measurable cost.
Robotics and autonomous systems are the largest growth area. Ground robots, delivery platforms, autonomous mowers, and agricultural robots depend on centimeter accuracy for path following and obstacle avoidance. A network also removes the on-site infrastructure that field robotics teams would otherwise have to deploy and maintain: TRIC Robotics runs farm-scale autonomous robots covering hundreds of acres per machine without a single on-site base station.
Automotive applications include ADAS and lane-level navigation. Precision agriculture uses RTK for auto-steer guidance, pass-to-pass alignment, and variable-rate application, where repeatability over time matters as much as absolute accuracy; see What is Precision Agriculture? Drone operations use it for mapping and inspection, and machine control systems use it to follow design specifications in real time.
In GNSS-degraded environments such as urban canyons, tunnels, and dense canopy, RTK is typically paired with an inertial navigation system so dead reckoning can bridge outages. How tightly those systems integrate has real consequences for performance; see Loose vs. Tight Coupling in GNSS/INS and The Navigation Engine: Correcting Imperfect Sensors in Real Time.
FAQs
What is the difference between an RTK network and Network RTK?
An RTK network is the physical infrastructure: reference stations at surveyed locations plus the service that distributes their corrections. Network RTK is a correction method that interpolates observations from several of those stations to synthesize a virtual station at your rover’s location. You can use an RTK network without using Network RTK, by connecting to a single nearest station instead.
What is a Virtual Reference Station (VRS)?
A VRS is synthesized correction data describing what a base station at your rover’s exact location would observe, generated by interpolating observations from several real surrounding stations. Your receiver treats it like a nearby physical base. VRS is a delivery format rather than a correction method, so it tells you how corrections arrive, not how they were computed.
Should I use single-baseline RTK or Network RTK?
Both deliver 1 to 3 cm accuracy on a dense network, so it depends on what your application values. Single-baseline gives you a deterministic, replayable correction chain and degradation you can observe directly, which helps when debugging autonomous systems. Network RTK gives you redundancy if a station goes offline, and better performance when your rover sits between several stations. Point One delivers both within True RTK, so you can switch between them or configure a fallback rather than committing to one.
What is the difference between True RTK, Network RTK, and Virtual RTK?
True RTK is Point One’s centimeter-accuracy service, and it includes both single-baseline and Network RTK (VRS) as configurable modes, each delivering 1 to 3 cm. Network RTK is the correction method that interpolates a virtual station from several physical ones. Virtual RTK is a separate service that runs SSR modeling on the backend and outputs standard RTCM, giving 3 to 7 cm with roughly 30-second convergence across continental coverage. All work with any dual-band RTK receiver.
Does an RTK network need an internet connection?
Corrections delivered over NTRIP require a connection, usually cellular. Two alternatives do not. A local base station can transmit over a UHF or VHF radio link, though range is typically under 10 km and requires line of sight. L-Band satellite delivery broadcasts corrections from geostationary satellites directly to the rover, which removes the cellular dependency and suits agriculture, mining, and remote operations.
How far can I be from a base station and still get centimeter accuracy?
Single-baseline performance typically begins degrading beyond roughly 30 to 40 km, with accuracy falling about 1 to 1.5 cm per additional 10 km. Network RTK extends usable range by keeping the effective baseline short through interpolation. Either way, the density of the underlying network is the limiting factor, not the correction method.
How many base stations does an RTK network need?
There is no single number, because what matters is spacing rather than total count. Networks with 30 to 40 km average station spacing keep both single-baseline and Network RTK in a predictable accuracy range. A network can advertise national coverage and still leave you 70 km or more from the nearest station, which is why published station locations are more informative than a shaded coverage map.
What is the difference between a public and a private RTK network?
Public networks are typically free, operated by government agencies or universities, and offer no uptime guarantee, limited monitoring, and little support. Private networks charge a subscription and typically add contractual uptime, continuous monitoring with failover, technical support, and API-based device provisioning. For production systems where a silent correction outage has a measurable cost, those commitments are usually the deciding factor.
What is the difference between GPS and RTK?
GPS is one satellite constellation, accurate on its own to roughly 3 to 10 meters. RTK is a correction technique that improves satellite positioning to 1 to 3 centimeters by applying real-time corrections from a reference station. Modern RTK uses multiple constellations (GPS, GLONASS, Galileo, and BeiDou), so “RTK GPS” is a legacy term; multi-constellation is the default.
Get Started with the Point One RTK Network
The Point One RTK Network is built for production positioning, from robotics and autonomy to precision agriculture and machine control.
- 4,000+ reference stations across the US, Europe, the UK, Canada, and Australia
- 30 to 40 km average station spacing
- Single-baseline and Network RTK both included in True RTK, switchable by profile, with SSR-based Virtual RTK available for wide-area fleets
- 99.9% uptime with continuous network monitoring
- Single mount point for global operation, with no manual station selection
- Receiver-agnostic, working with any RTCM 3.x and NTRIP-compatible hardware
- GraphQL API for provisioning, observability, and fleet management
For positioning through GNSS-degraded environments, the Positioning Engine adds sensor fusion and dead reckoning on top of corrections.
Read the announcement: Single-Baseline or Network RTK? True RTK Now Delivers Both.
Explore current station locations on the coverage map, or start a free trial to evaluate performance in your operating environment. For fleet deployments and coverage questions, contact sales.